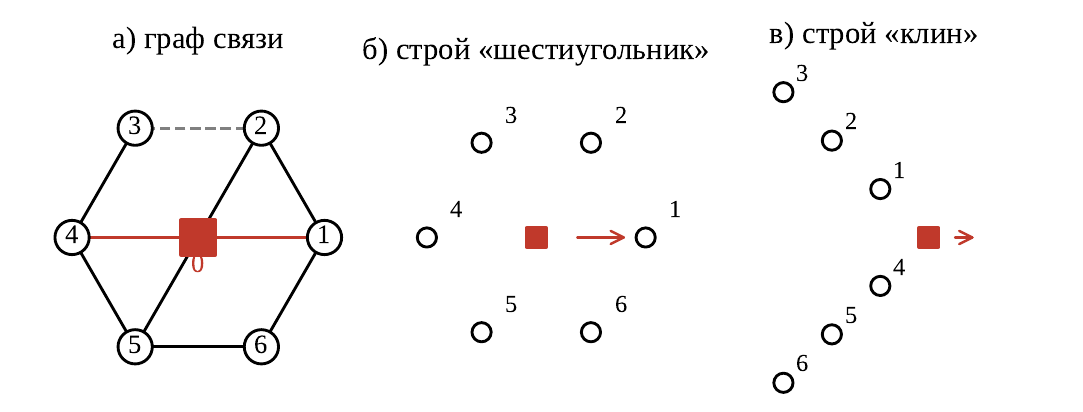
An adaptive gain-tuning rule I borrowed from classic multi-agent systems literature kept a six-drone swarm in formation better than the alternatives: during a wind gust, the error was 0.36 m, compared with 0.89 m for a manually tuned controller. But at least one drone was operating at its thrust limit 67% of the time, and control effort was 3.5 times higher. The controller gains surged with every major maneuver and never came back down. In this article, I'll explain what causes this effect and how a single line in the adaptation rule turns it into a manageable trade-off between precision and energy use.
This piece draws on a paper I coauthored with my academic adviser, V. V. Semenov, and is part of my graduation thesis in the Department of Engineering Cybernetics at the National University of Science and Technology MISIS.
Read more